Robotics · Product development
ID-0
A mobile robot that designs, 3D-prints and fits its own gripper when it meets an object it can't hold.
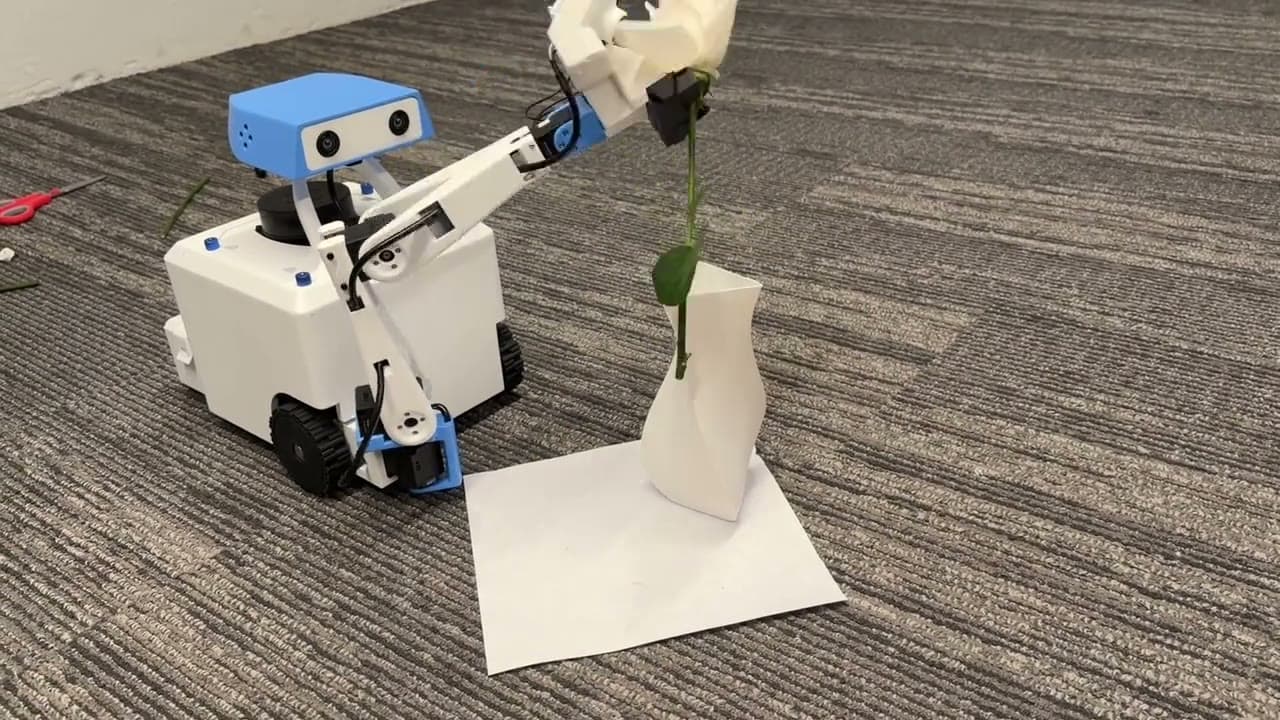
ID-0 is a mobile robot that makes its own tools. When it meets an object it has no gripper for, it looks at the object, designs an end effector to fit it, 3D-prints the part and swaps it on, then gets on with the task. In the demo, the task is standing a fallen, twisted 3D-printed vase back up and putting a rose in it.
Reading the object. From a camera view to design inputs and risks.
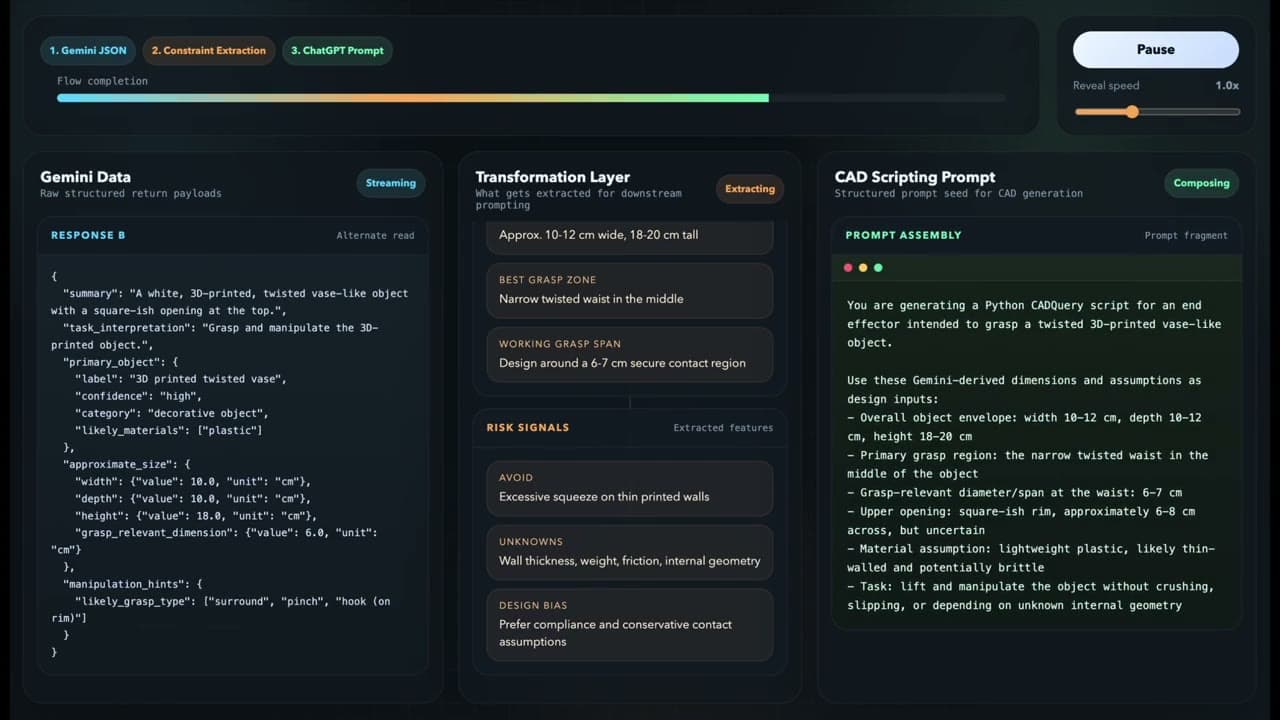
A vision model (Gemini) returns a structured read of the object: a white, 3D-printed twisted vase, roughly 10 cm wide and 18 cm tall, best grasped at its narrow waist, and probably thin-walled plastic. A transformation layer turns that into design inputs (the overall envelope, the best grasp zone and a 6–7 cm working grasp span) along with risk signals: don't squeeze the thin printed walls, treat wall thickness, weight and friction as unknowns, and lean toward compliance and conservative contact.
Designing the gripper. A coding agent writes the CAD generator.
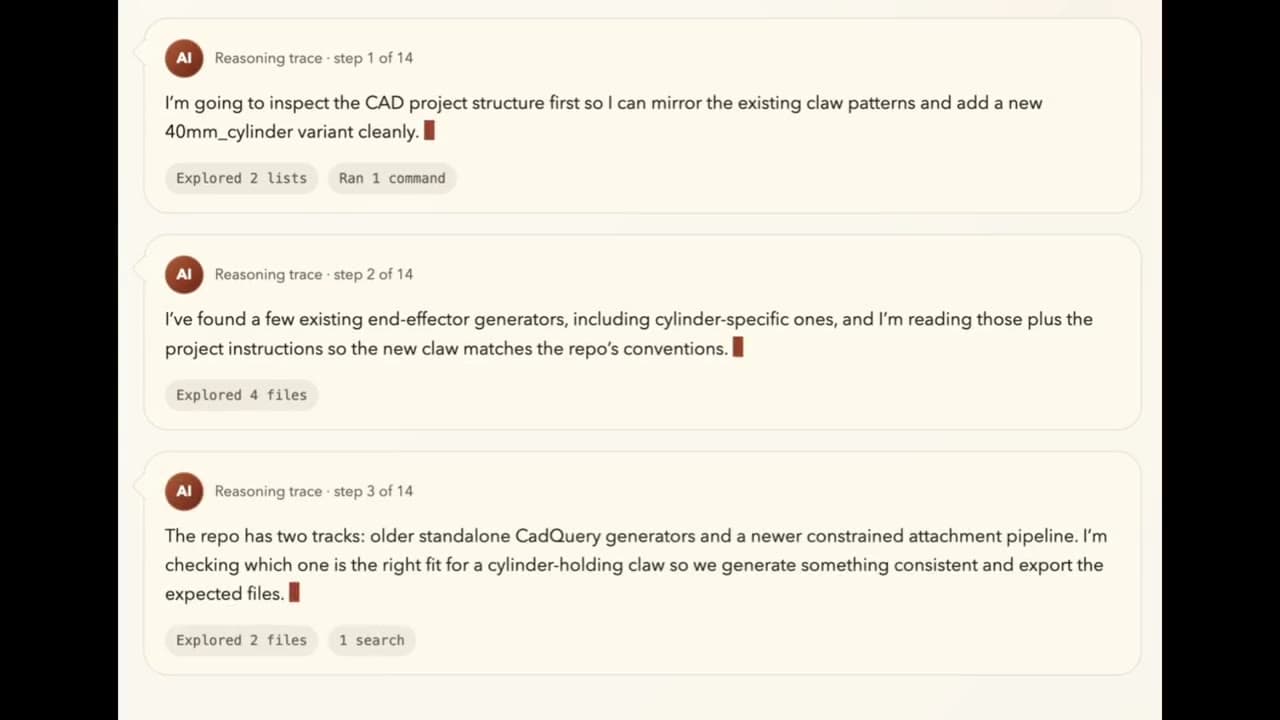
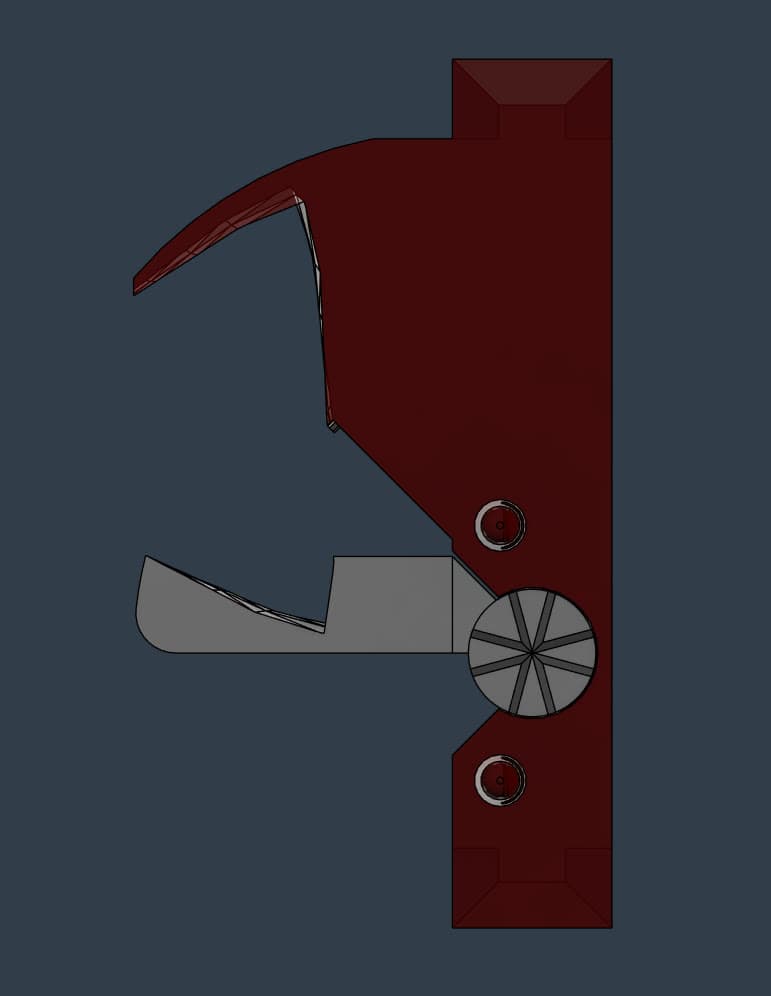
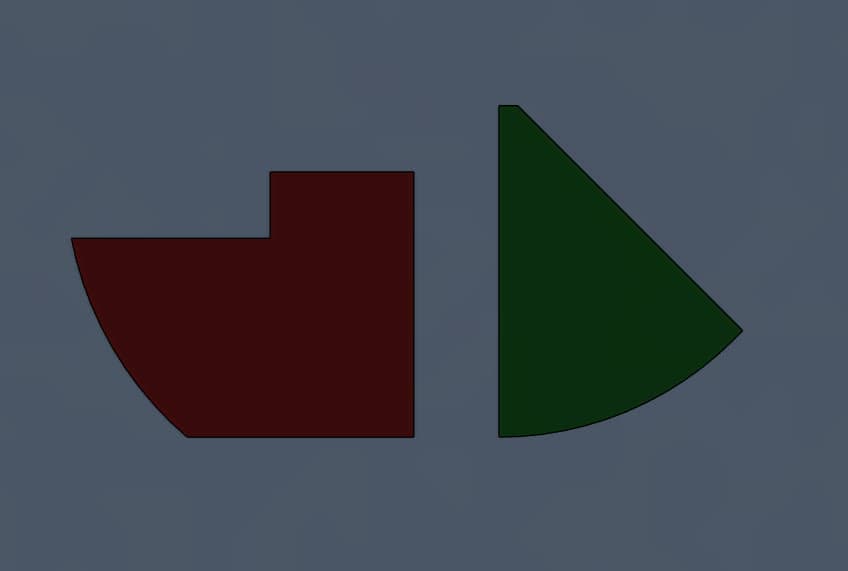
Those inputs are assembled into a CAD scripting prompt. A coding agent then works inside the CAD repository: it reads the existing end-effector generators and the project's conventions, picks the right pipeline, writes a new parametric CadQuery generator, builds the geometry to check it and exports STEP and STL files.
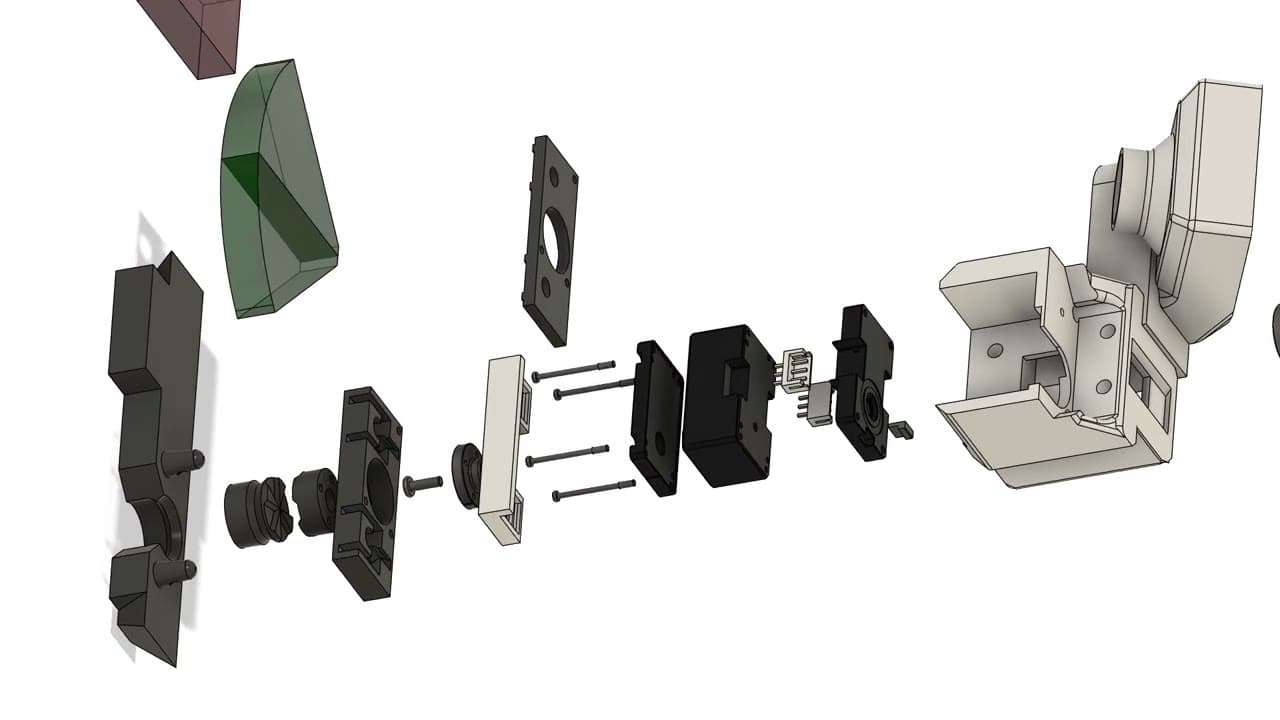
Mechanism CAD
Printing and tool change. Off the printer, onto the wrist, back to the task.
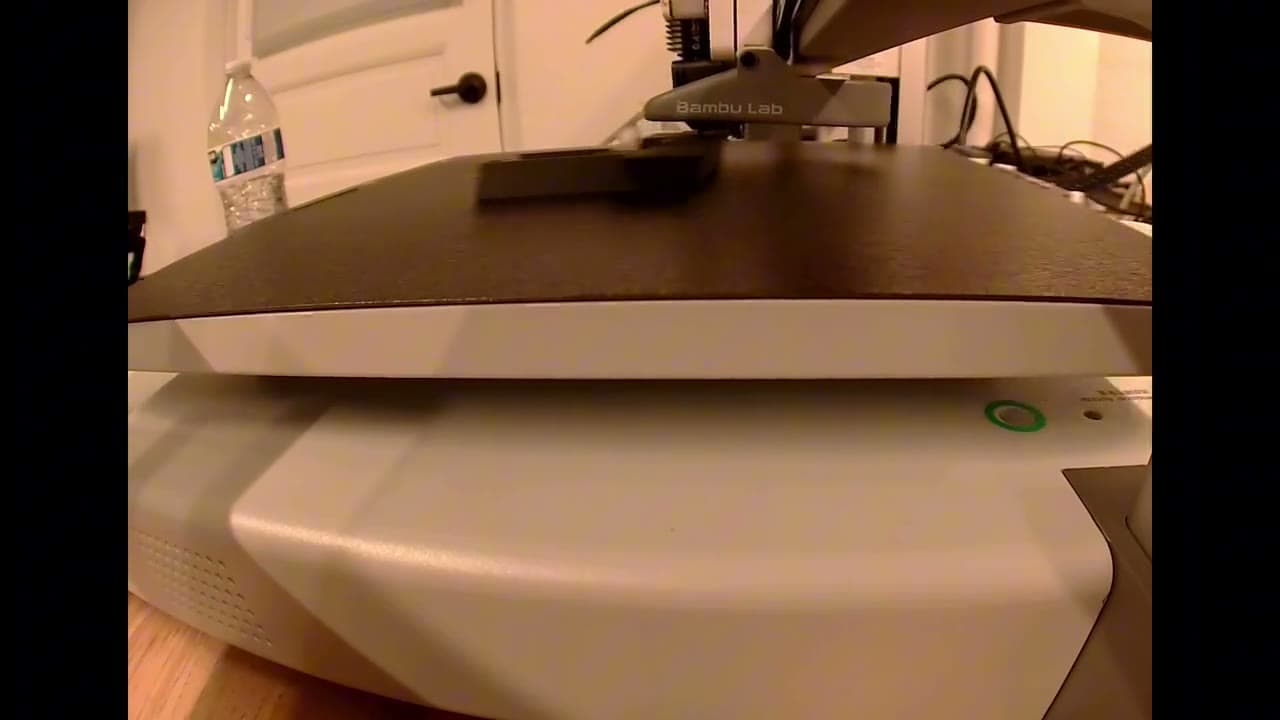
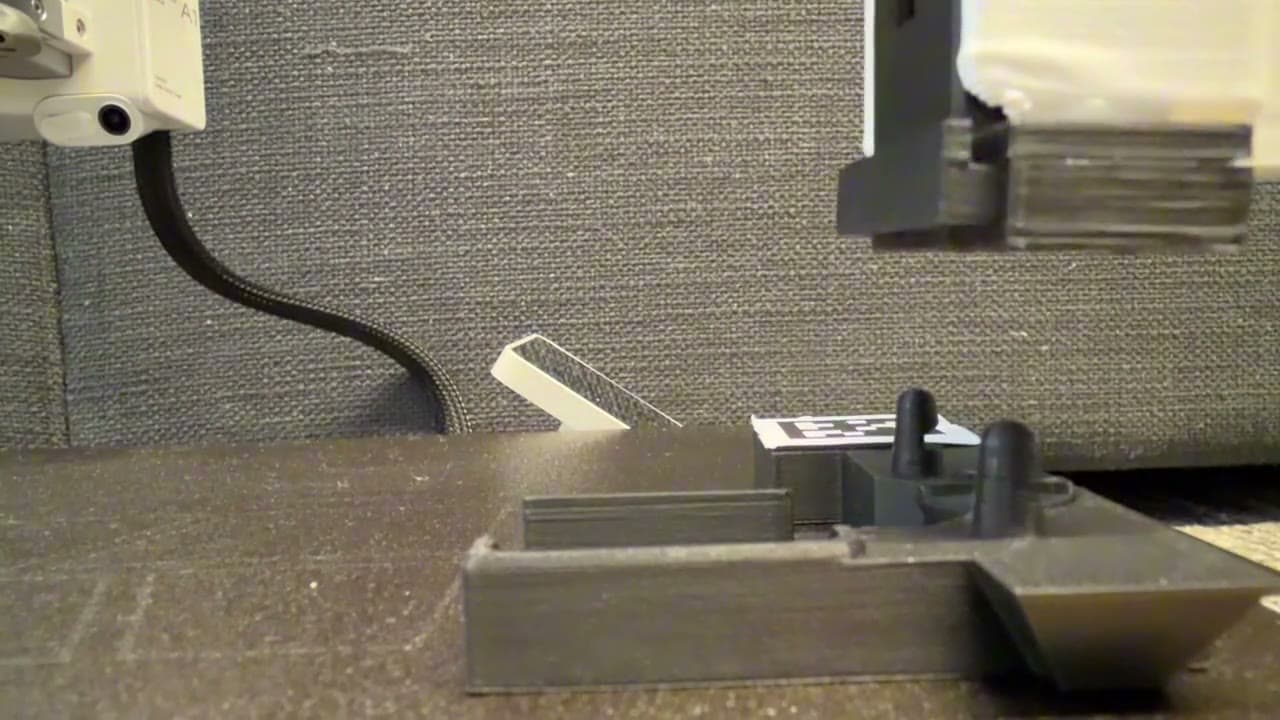
The new end effector prints on a Bambu Lab printer. The robot drives to the printer, finds the part on the bed by its AprilTag, docks it onto its wrist through a tool changer and goes back to the vase, finishing with the rose standing in it.
Team. The team outside the office.